Publications
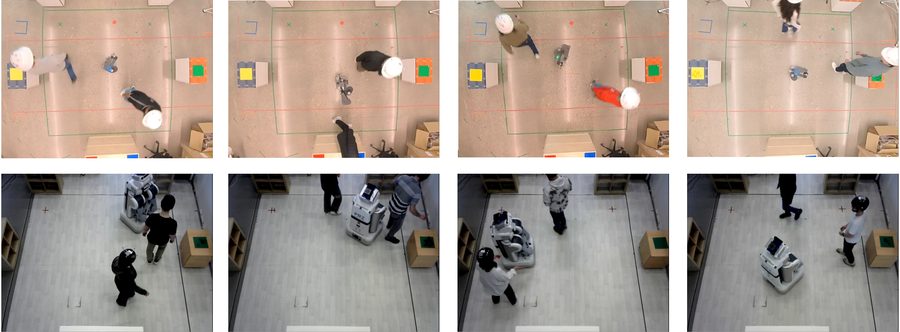
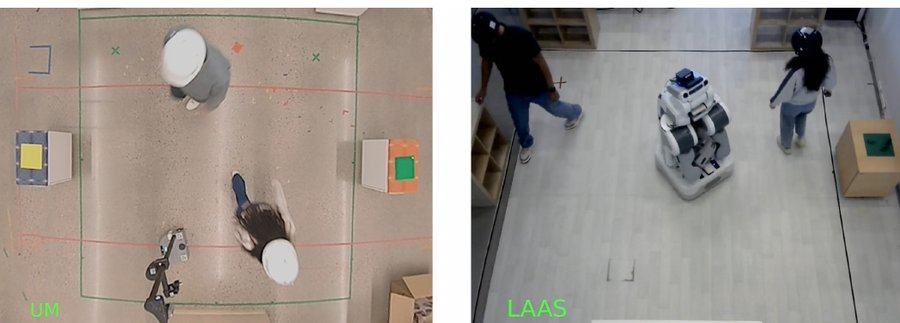
Bi3: A Biplatform, Bicultural, Biperson Dataset for Social Robot Navigation
IEEE International Conference on Robotics and Automation (ICRA) 2026
A dataset of close social robot navigation encounters between two humans and a robot, collected across two robot platforms and two sites (USA and France) with 74 participants. Bi3 provides 10.5 hours of multimodal human/robot motion tracks, RGB video, and u...
How Human Motion Prediction Quality Shapes Social Robot Navigation Performance in Constrained Spaces
HRI 2026
We study how the accuracy of human motion prediction modules propagates through to downstream social navigation performance in tight, constrained spaces, where small prediction errors have outsized effects on planner behavior and human comfort.
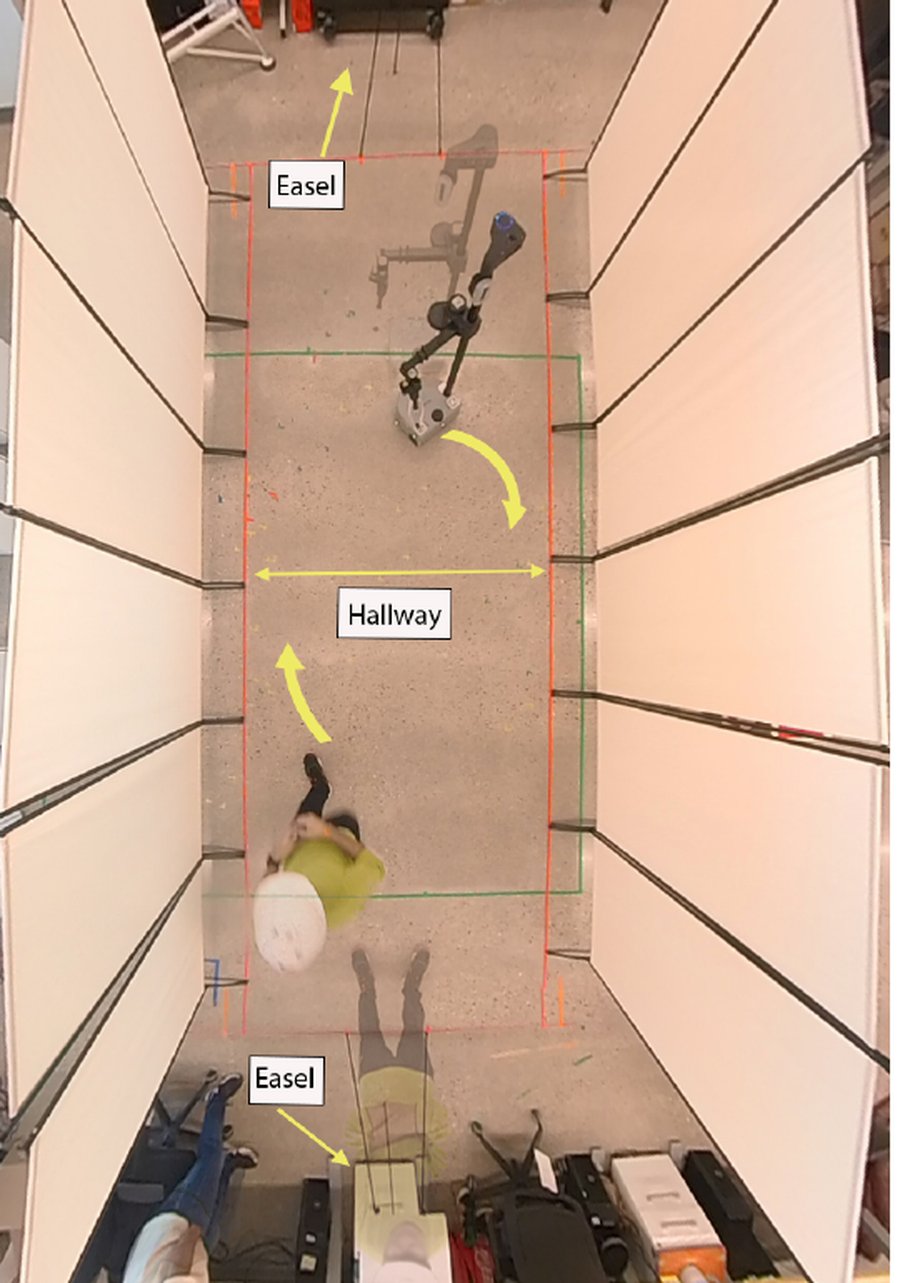
Rethinking Legibility in Social Robot Navigation: Impact of Intent Representation and Human Attention
HRI 2026 Late Breaking Reports
Legible robot motion lets nearby people anticipate what a robot will do next, but most prior work on legibility assumes open spaces, static interactions, and fully attentive pedestrians. Through two hallway user studies with a Hello Robot Stretch 2, we show...
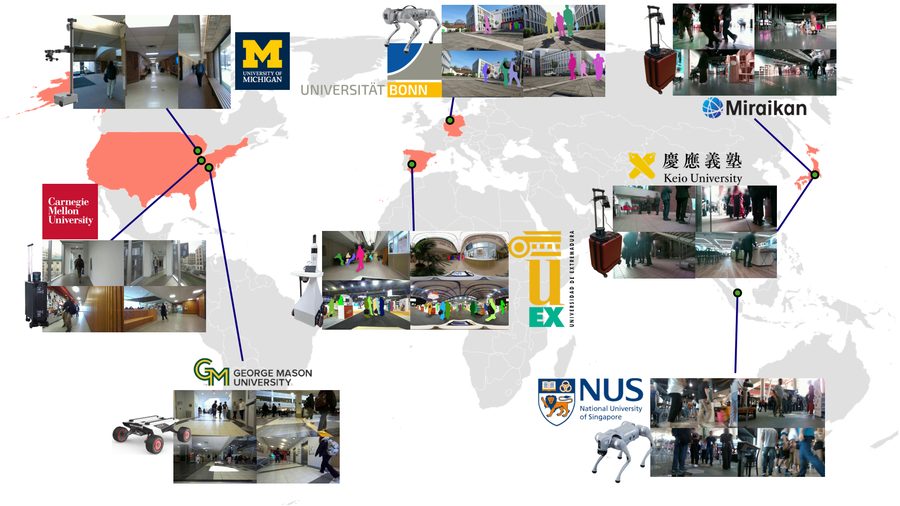
ACME: A Multi-Cultural, Multi-Embodiment Social-Navigation Dataset
Under review, International Journal of Robotics Research (IJRR)
A large-scale social navigation dataset collected across 8 sites in 5 countries with 7 robot embodiments, comprising 29.35 hours of onboard robot data and 43.5 hours of overhead pedestrian tracking, built to capture how culture, geography, and embodiment sh...
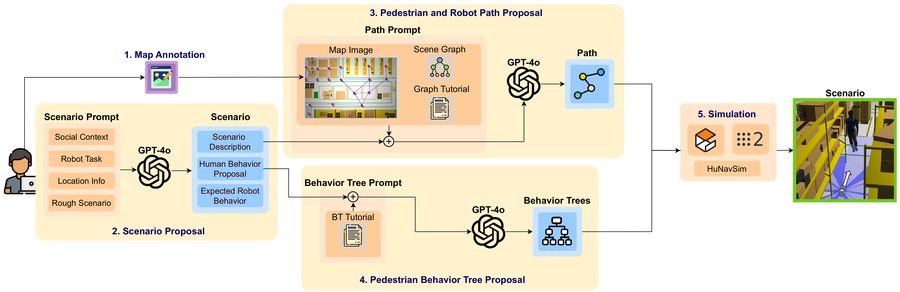
SocRATES: Towards Automated Scenario-based Testing of Social Navigation Algorithms
IEEE Robotics and Automation Letters (RA-L)
SocRATES is an LLM-powered ROS2/Gazebo pipeline that automatically generates diverse, realistic test scenarios for social navigation algorithms and surfaces failure cases across varied human behaviors and contexts. Code: github.com/clear-nus/SocRATES.
Towards Automated Scenario Testing of Social Navigation Algorithims
Unsolved Problems in Social Navigation workshop, RSS 2024
Use Google Scholar for full citation
LTLDoG: Satisfying Temporally-Extended Symbolic Constraints for Safe Diffusion-Based Planning
IEEE Robotics and Automation Letters
Use Google Scholar for full citation
Towards Automated Void Detection for Search and Rescue with 3D Perception
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Use Google Scholar for full citation
A Comparison of Point Cloud Registration Techniques for on-site Disaster Data from the Surfside Structural Collapse
2022 IEEE International Symposium on Safety, Security, and Rescue Robotics (SSRR)
Use Google Scholar for full citation
AI-based face recognition and skin pixel recognition for computer vision applications
Hindi Technical Seminar, CSIR - Structural Engineering Research Centre, Chennai, September 2021
The paper introduces a new threshold based skin and face detection method for extracting remote PPG signals for monitoring cardiac health. The propsed threshold values for skin pixels are tailored for the various skin tone found in Indian subcontinent regio...