About Me
I am a PhD candidate in Robotics at the University of Michigan, advised by Prof. Christoforos Mavrogiannis in the Fluent Robotics Lab. I study motion planning and decision-making for robots operating around people, with a focus on how robot motion communicates intent and how human behavior affects navigation.
I develop and deploy embodied AI systems for robots operating alongside people, connecting perception, planning, and control with real-world studies of human–robot interaction.
I am seeking a Summer 2027 research internship in robot planning, robot learning, or human–robot interaction.
CV · Google Scholar · GitHub · Email
My current research focuses on learning from multimodal cues to understand human behavior and the surrounding environment. I study how this contextual understanding can guide robots toward more informed and adaptive decision-making around people.
Previously I worked with Prof. Harold Soh at NUS’s CLeAR Lab on diffusion-based planning, and with Prof. Howie Choset and Prof. Robin Murphy at CMU’s Biorobotics Lab during my undergrad at BITS Pilani Goa.
Selected Publications
Human Behavior and Robot Interaction
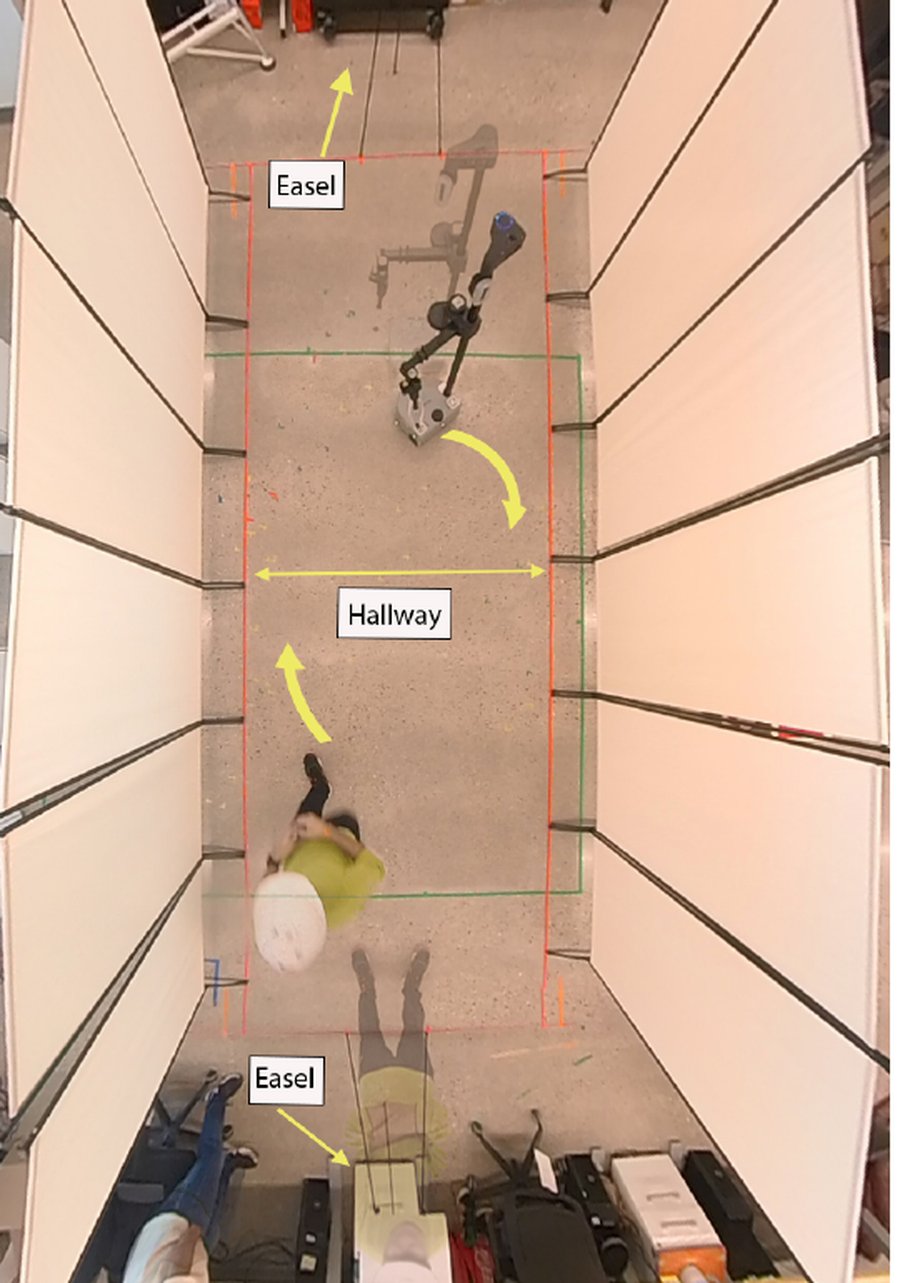
Intent Representation and Human Distraction Modulate the Effects of Legible Robot Motion in Hallway Navigation
Accepted to ACM Transactions on Human-Robot Interaction (THRI), 2026
Planning and Control
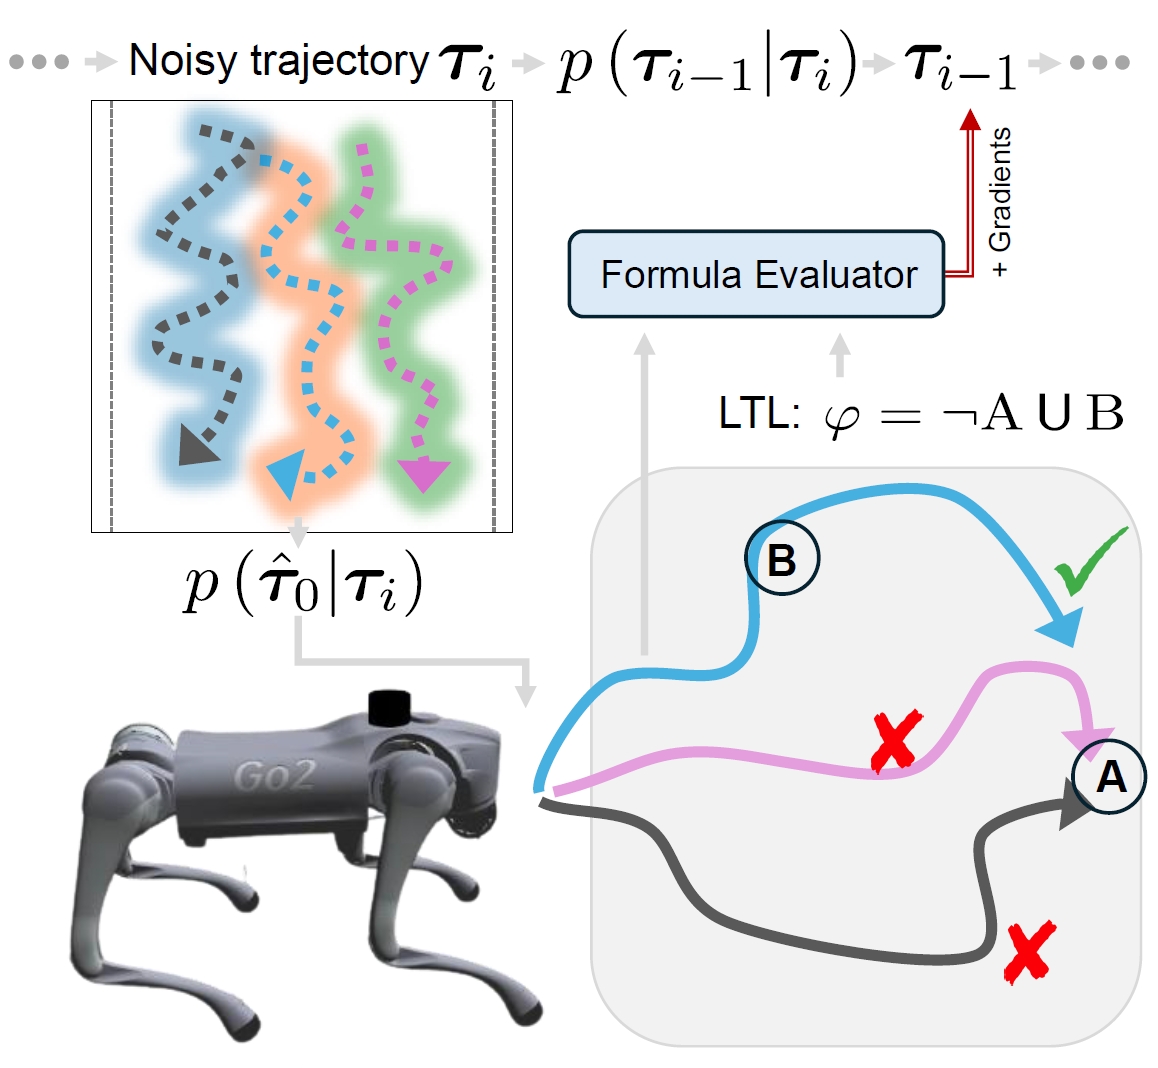
LTLDoG: Satisfying Temporally-Extended Symbolic Constraints for Safe Diffusion-Based Planning
IEEE Robotics and Automation Letters
Robot Systems and Evaluation
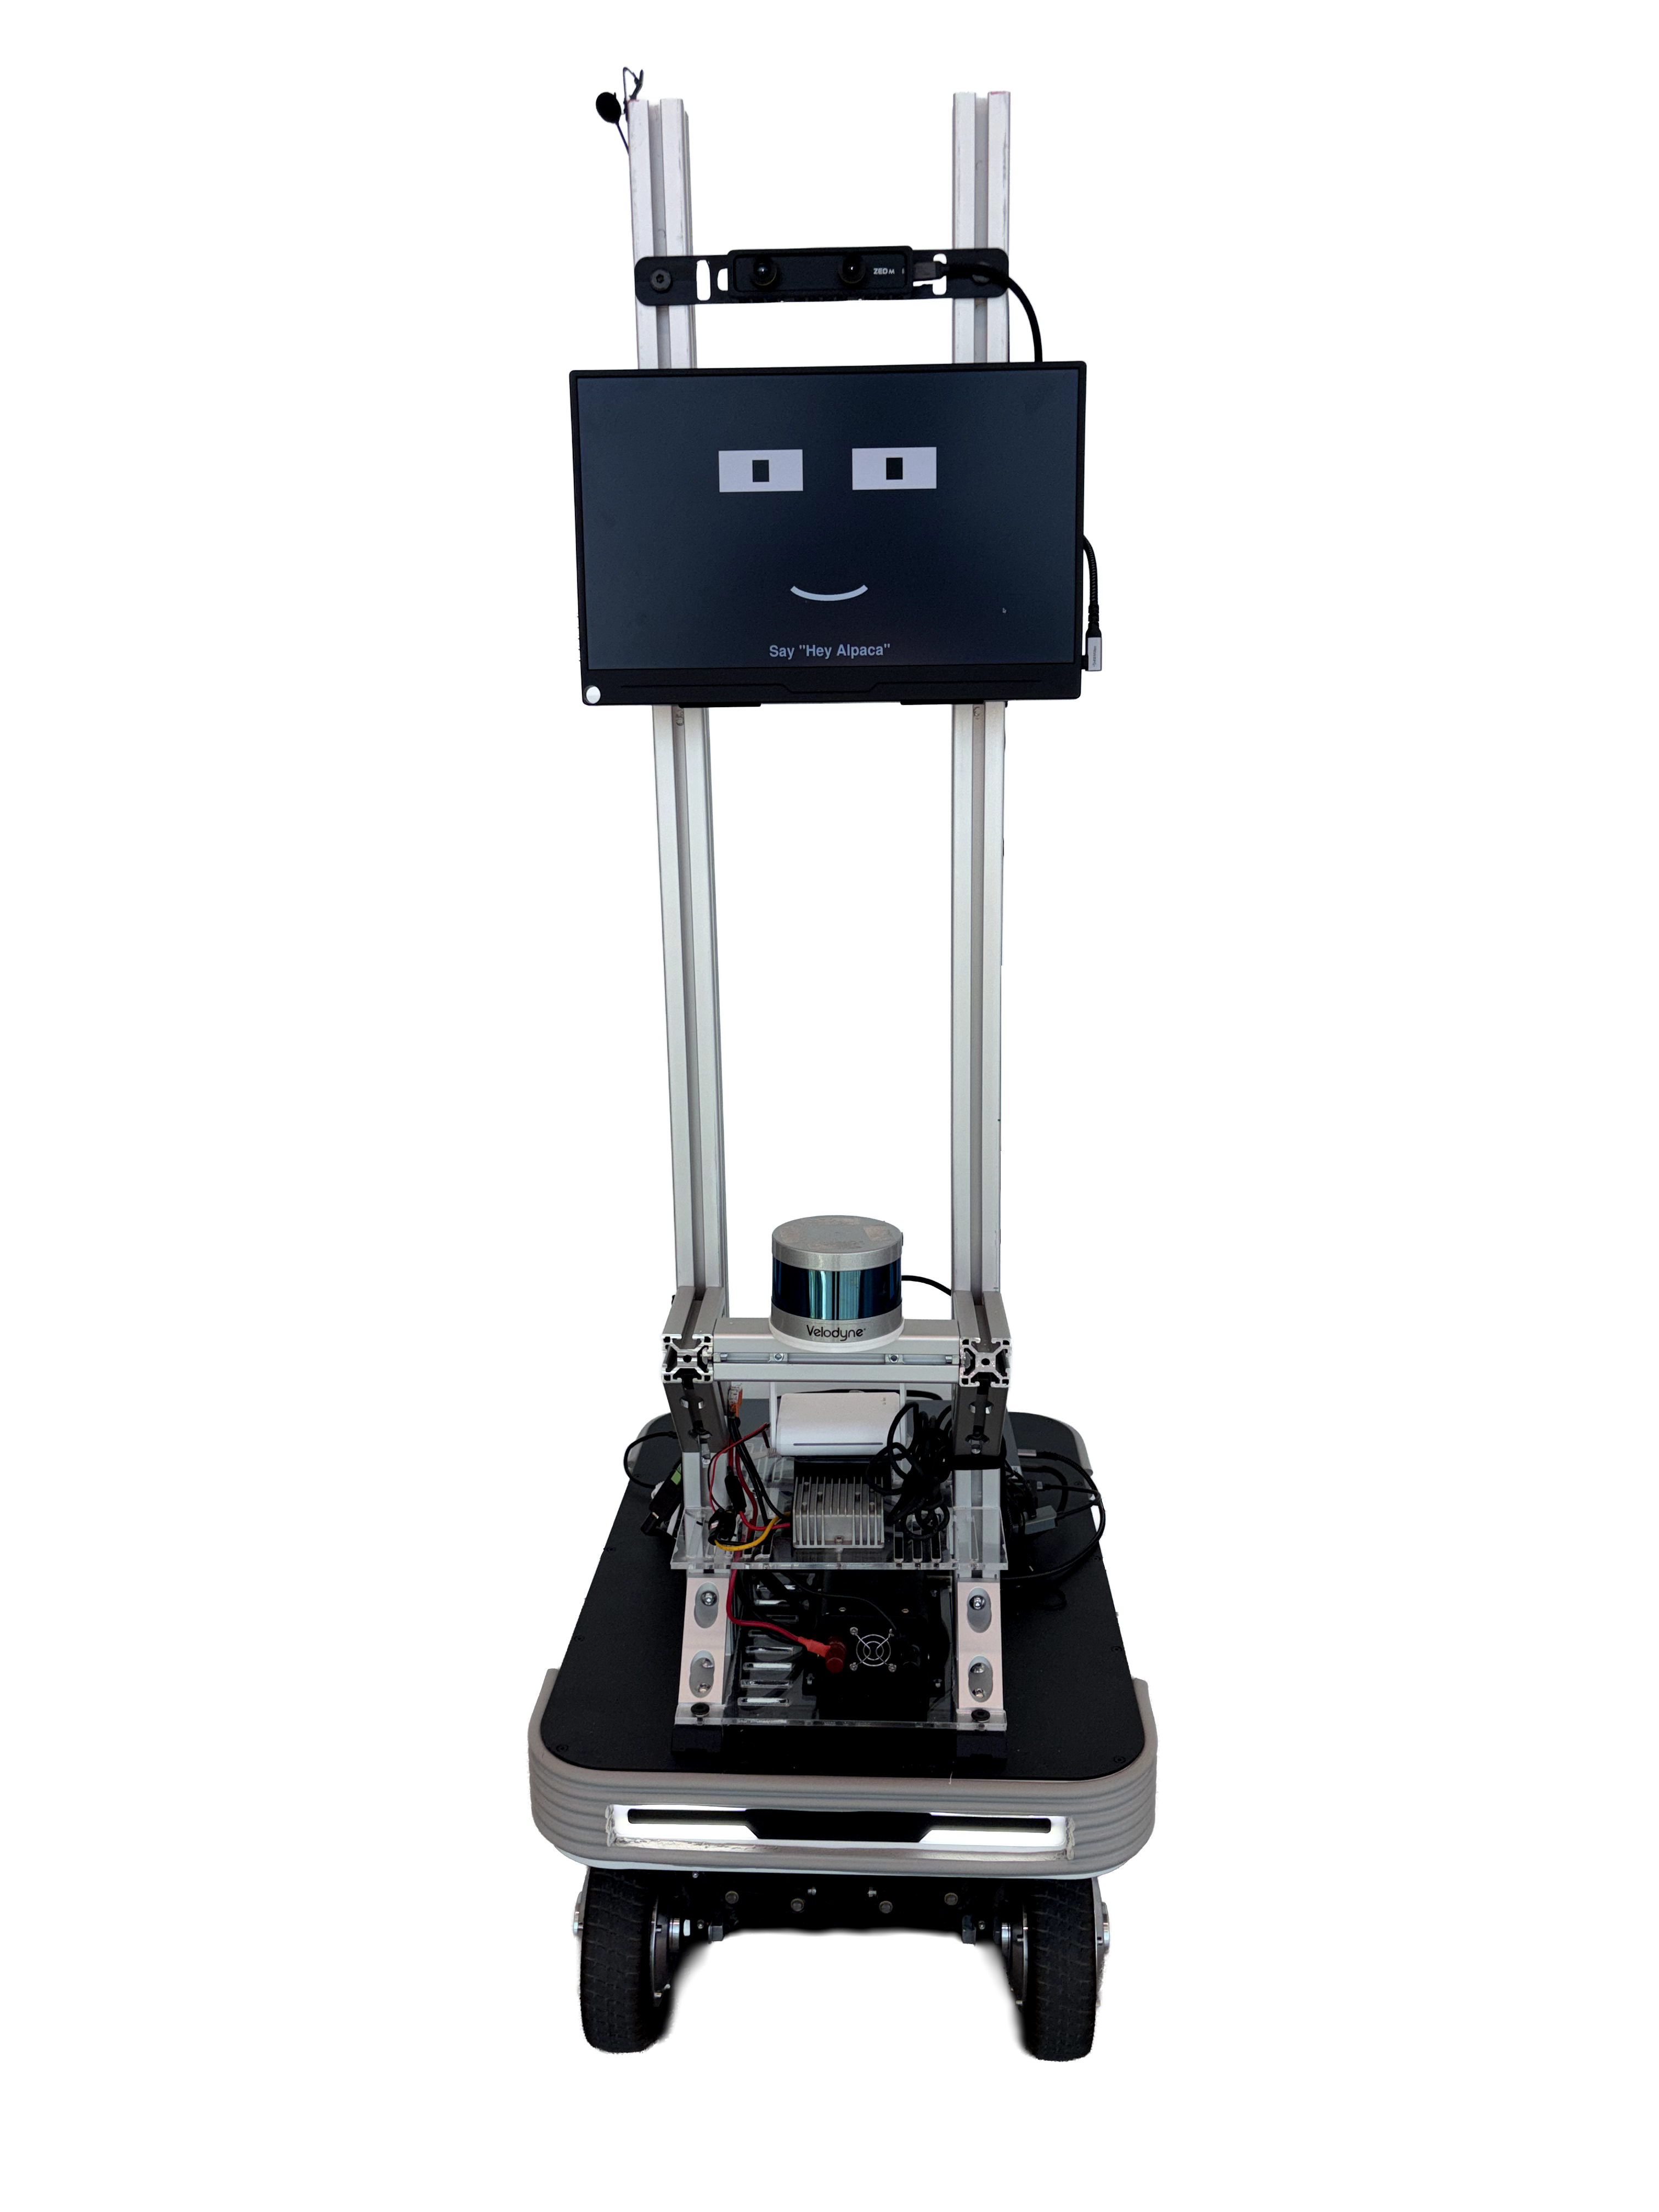
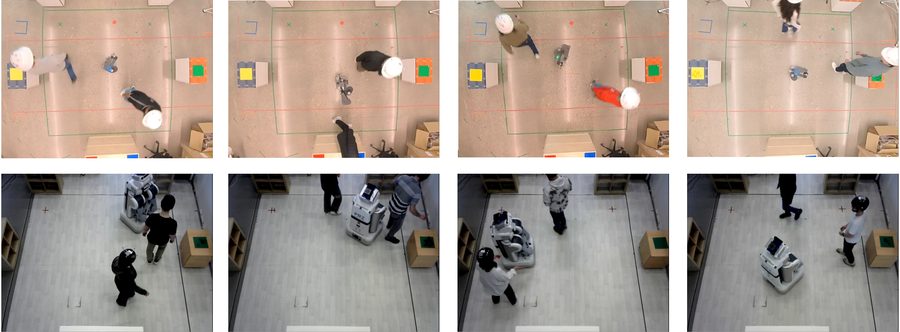
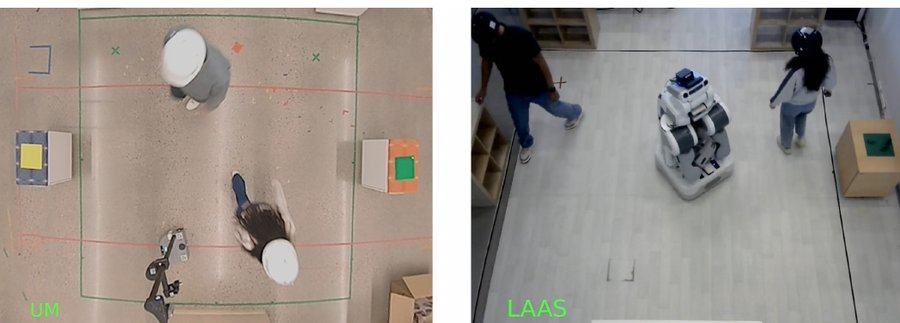
Bi3: A Biplatform, Bicultural, Biperson Dataset for Social Robot Navigation
IEEE International Conference on Robotics and Automation (ICRA) 2026
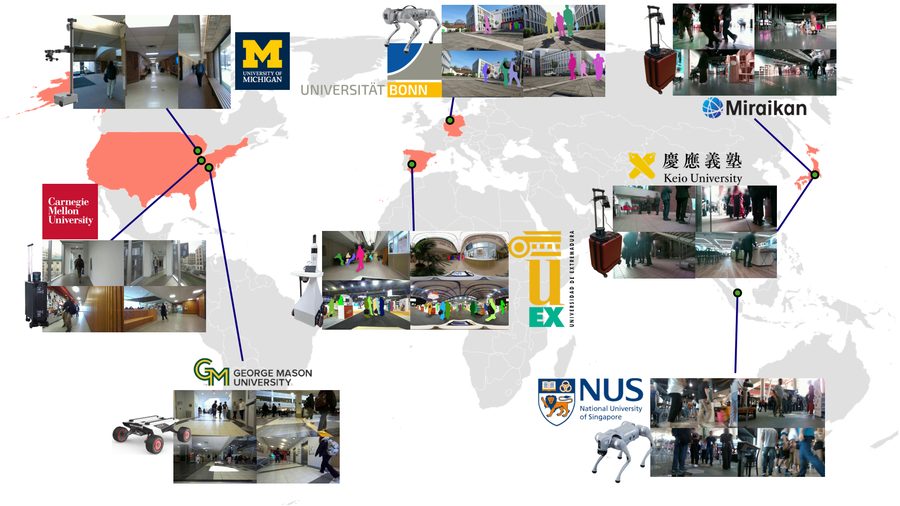
ACME: A Multi-Cultural, Multi-Embodiment Social-Navigation Dataset
Under review, International Journal of Robotics Research (IJRR)
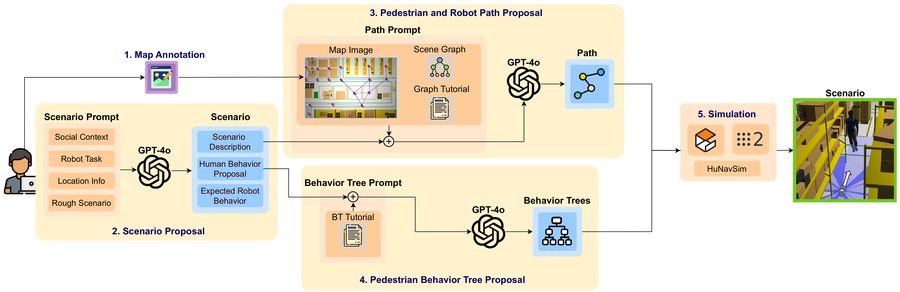
SocRATES: Language-Driven Scenario Generation for Evaluating Social Navigation Algorithms
IEEE Robotics and Automation Letters (RA-L), 2026
See my full publication list and research experience for all projects, papers, and roles.
News
- THRI 2026. Our paper, Intent Representation and Human Distraction Modulate the Effects of Legible Robot Motion in Hallway Navigation, has been accepted to ACM Transactions on Human-Robot Interaction.
- ICRA 2026. Bi3, A Biplatform, Bicultural, Biperson Dataset for Social Robot Navigation.
- HRI 2026. How Human Motion Prediction Quality Shapes Social Robot Navigation Performance.